A ‘5-in-1’ seed-sized surgical robot
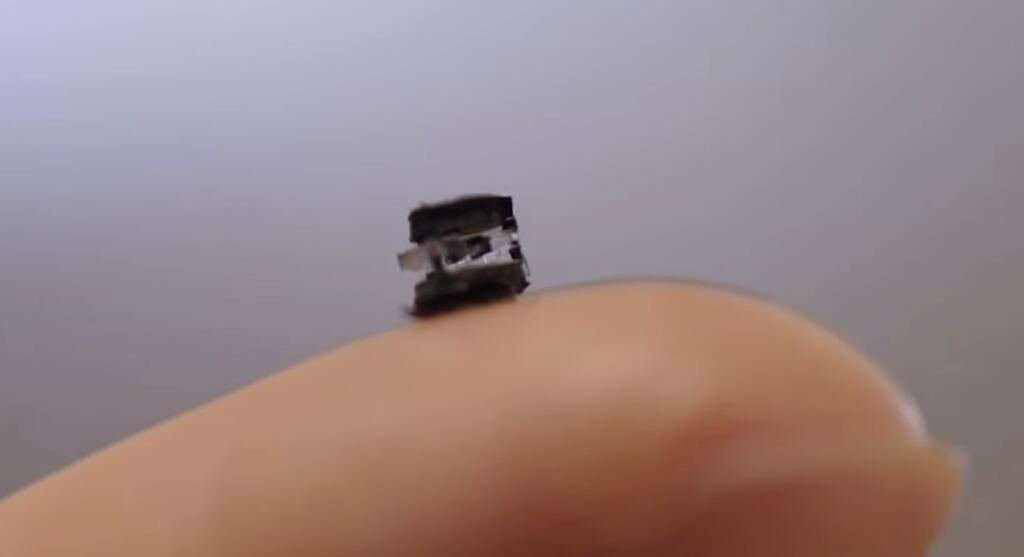
RoboHub News — scientists from Nanyang Technological University, Singapore (NTU Singapore) have developed a tiny seed-sized robot that can navigate across soft and uneven surfaces to perform five surgical functions wirelessly, paving the way for developing robots to make surgeries and medical treatments more precise. The miniature robot, measuring just 4.4 mm in length and controlled by weak magnetic fields, can move, cut biological tissues, release drugs, grip and store tissue samples, or generate heat remotely at any one time.
It takes under a second to switch between these functions. Led by Associate Professor Lum Guo Zhan from NTU’s School of Mechanical and Aerospace Engineering (MAE), the work was recently published in the academic journal Advanced Materials. Using magnetic coils in the laboratory to remotely control the robot, the team was able to make the robot deploy different tools and perform different functions, such as activating a tiny blade to cut through tissue, or emitting heat to a targeted area, which could be relevant for approaches being studied that use heat for cancer treatment. “Most magnetic robots like this can perform only one or two functions. Our latest invention can now do five, and our long-term goal is for doctors to use these mini robots in the body, navigate them to a targeted location, and use them to perform treatments,” said Assoc Prof Lum, who is a pioneer in miniature robots made from soft, flexible materials. Mini robots are being studied worldwide as a possible way to make minimally invasive surgical and medical procedures safer, less painful and more precise. Such devices could one day allow doctors to carry out targeted surgeries deep inside the body without large cuts or bulky surgical instruments. Overcoming a key robotics challenge To fit multiple functions into a robot only a few millimetres long, the NTU team developed a device for controlling movements that is activated by magnetic fields and which can be reprogrammed in under a second. The robot is made from soft magnetic materials, including PDMS and Ecoflex, which are silicone-based materials commonly used in soft robotics as they are flexible and can be shaped into small structures. These materials are embedded with magnetic microparticles measuring 5 micrometres each, allowing different parts of the robot to respond to magnetic fields. At the centre of the device is a magnetic module that can be magnetised, demagnetised and remagnetised in different directions. Each magnetic orientation activates a different function of the robot, allowing the same mobile robot to perform five different functions, including cutting and grasping tissues. The researchers also engineered different regions of the robot to ensure that only one part, but not the rest, responds to the same magnetic field. This means that only one part of the robot reacts to a magnetic field to change its shape to activate a tool or function, while other parts remain still and unchanged in their current forms, addressing a major limitation in miniature magnetic robots. At small scales, magnetic fields often affect the entire device at once, causing it to behave like a single magnet, with all parts reacting to a magnetic field, thus limiting how precisely it can move or activate different tools.